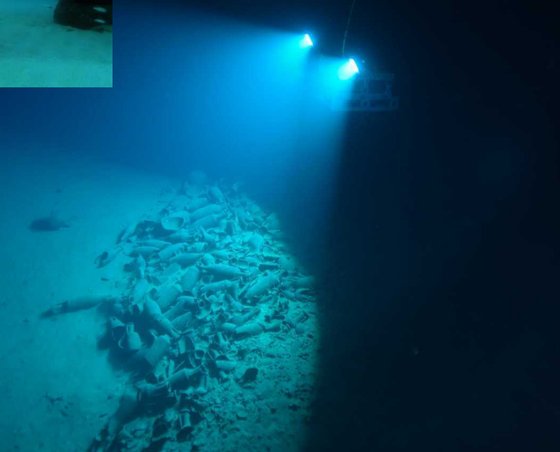
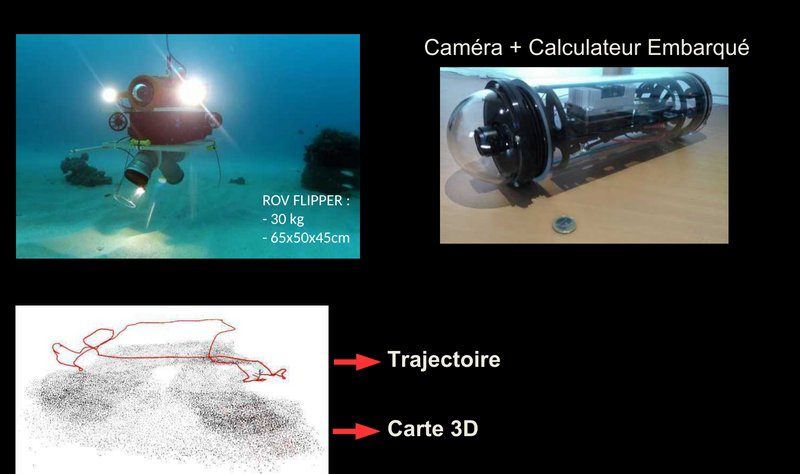
@inproceedings{jouclas2026photogrammetry,title={Photogrammetry-Aware Next-Best-View Planning for Autonomous Underwater {3D} Reconstruction},author={Jouclas, Louis and Ferrera, Maxime and Dune, Claire and Creuze, Vincent and Hugel, Vincent},booktitle={OCEANS 2026},year={2026}}
2024
3DV
SUCRe: Leveraging Scene Structure for Underwater Color Restoration
Clémentin Boittiaux, Ricard Marxer, Claire Dune, and 3 more authors
In International Conference on 3D Vision (3DV), 2024
@inproceedings{boittiaux2024sucre,title={{SUCRe}: Leveraging Scene Structure for Underwater Color Restoration},author={Boittiaux, Cl{\'e}mentin and Marxer, Ricard and Dune, Claire and Arnaubec, Aur{\'e}lien and Ferrera, Maxime and Hugel, Vincent},booktitle={International Conference on 3D Vision (3DV)},pages={1488--1497},year={2024},}
2023
IJRR
Eiffel Tower: A Deep-Sea Underwater Dataset for Long-Term Visual Localization
Clémentin Boittiaux, Claire Dune, Maxime Ferrera, and 5 more authors
The International Journal of Robotics Research, 2023
@article{boittiaux2023eiffel,title={Eiffel Tower: A Deep-Sea Underwater Dataset for Long-Term Visual Localization},author={Boittiaux, Cl{\'e}mentin and Dune, Claire and Ferrera, Maxime and Arnaubec, Aur{\'e}lien and Marxer, Ricard and Matabos, Marjolaine and Van Audenhaege, Lo{\"i}c and Hugel, Vincent},journal={The International Journal of Robotics Research},volume={42},number={9},pages={689--699},year={2023},doi={10.1177/02783649231177322},}
JMSE
Underwater 3D Reconstruction from Video or Still Imagery: Matisse and 3DMetrics Processing and Exploitation Software
Aurélien Arnaubec, Maxime Ferrera, Javier Escartín, and 3 more authors
@article{arnaubec2023matisse,title={Underwater {3D} Reconstruction from Video or Still Imagery: {Matisse} and {3DMetrics} Processing and Exploitation Software},author={Arnaubec, Aur{\'e}lien and Ferrera, Maxime and Escart{\'i}n, Javier and Matabos, Marjolaine and Gracias, Nuno and Opderbecke, Jan},journal={Journal of Marine Science and Engineering},volume={11},number={5},pages={985},year={2023},doi={10.3390/jmse11050985},}
OCEANS
Vision-based 3D Reconstruction for Deep-Sea Environments: Practical Use for Surveys and Inspection
Maxime Ferrera, Aurélien Arnaubec, Clémentin Boittiaux, and 2 more authors
@inproceedings{ferrera2023oceans,title={Vision-based {3D} Reconstruction for Deep-Sea Environments: Practical Use for Surveys and Inspection},author={Ferrera, Maxime and Arnaubec, Aur{\'e}lien and Boittiaux, Cl{\'e}mentin and Larroche, In{\`e}s and Opderbecke, Jan},booktitle={OCEANS 2023 - Limerick},pages={1--7},year={2023},}
2021
OCEANS
Combined use of a frame and a linear pushbroom camera for deep-sea 3D hyperspectral mapping
Peeyush Kumar, Nuno Gracias, Klemen Istenič, and 4 more authors
@inproceedings{kumar2021pushbroom,title={Combined use of a frame and a linear pushbroom camera for deep-sea {3D} hyperspectral mapping},author={Kumar, Peeyush and Gracias, Nuno and Isteni{\v{c}}, Klemen and Garcia, Rafael and Arnaubec, Aur{\'e}lien and Ferrera, Maxime and Bajjouk, Touria},booktitle={OCEANS 2021: San Diego -- Porto},pages={1--9},year={2021},}
ICCVW
Hyperspectral 3D Mapping of Underwater Environments
Maxime Ferrera, Aurélien Arnaubec, Klemen Istenič, and 2 more authors
In Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) Workshops, 2021
@inproceedings{ferrera2021hyperspectral,title={Hyperspectral 3D Mapping of Underwater Environments},author={Ferrera, Maxime and Arnaubec, Aur{\'e}lien and Isteni{\v{c}}, Klemen and Gracias, Nuno and Bajjouk, Touria},booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) Workshops},pages={3696--3705},year={2021},}
RA-L
OV²SLAM: A Fully Online and Versatile Visual SLAM for Real-Time Applications
Maxime Ferrera, Alexandre Eudes, Julien Moras, and 2 more authors
3rd place at the CVPR 2020 TartanAir visual SLAM challenge. Also presented at ICRA 2021.
@article{ferrera2021ov2slam,title={{OV²SLAM}: A Fully Online and Versatile Visual {SLAM} for Real-Time Applications},author={Ferrera, Maxime and Eudes, Alexandre and Moras, Julien and Sanfourche, Martial and Le Besnerais, Guy},journal={IEEE Robotics and Automation Letters},volume={6},number={2},pages={1399--1406},year={2021},doi={10.1109/LRA.2021.3058069},}
2019
PhD
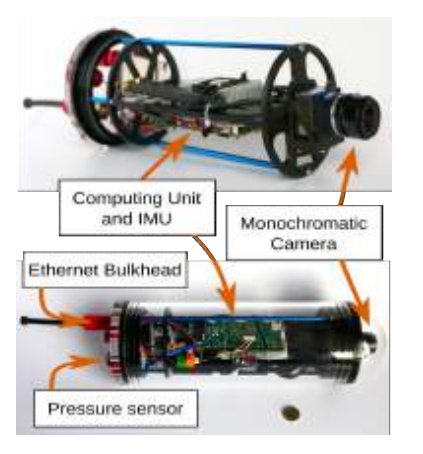
Monocular Visual-Inertial-Pressure Fusion for Underwater Localization and 3D Mapping
@phdthesis{ferrera2019phd,title={Monocular Visual-Inertial-Pressure Fusion for Underwater Localization and 3D Mapping},author={Ferrera, Maxime},school={Universit{\'e} de Montpellier},year={2019},}
IJRR
AQUALOC: An Underwater Dataset for Visual-Inertial-Pressure Localization
Maxime Ferrera, Vincent Creuze, Julien Moras, and 1 more author
The International Journal of Robotics Research, 2019
@article{ferrera2019aqualoc,title={{AQUALOC}: An Underwater Dataset for Visual-Inertial-Pressure Localization},author={Ferrera, Maxime and Creuze, Vincent and Moras, Julien and Trouv{\'e}-Peloux, Pauline},journal={The International Journal of Robotics Research},year={2019},}
3DV
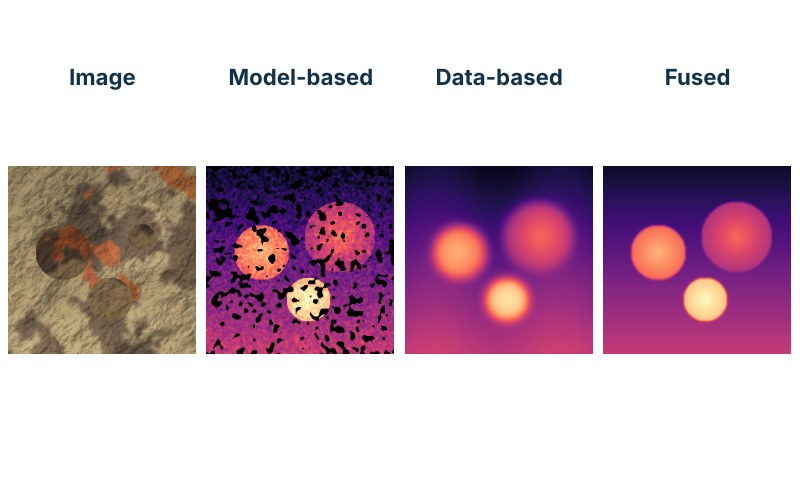
Fast Stereo Disparity Maps Refinement By Fusion of Data-Based And Model-Based Estimations
Maxime Ferrera, Alexandre Boulch, and Julien Moras
In International Conference on 3D Vision (3DV), 2019
@inproceedings{ferrera2019deeprefinement,title={Fast Stereo Disparity Maps Refinement By Fusion of Data-Based And Model-Based Estimations},author={Ferrera, Maxime and Boulch, Alexandre and Moras, Julien},booktitle={International Conference on 3D Vision (3DV)},year={2019},}
Sensors
Real-Time Monocular Visual Odometry for Turbid and Dynamic Underwater Environments
Maxime Ferrera, Julien Moras, Pauline Trouvé-Peloux, and 1 more author
@article{ferrera2019uwvo,title={Real-Time Monocular Visual Odometry for Turbid and Dynamic Underwater Environments},author={Ferrera, Maxime and Moras, Julien and Trouv{\'e}-Peloux, Pauline and Creuze, Vincent},journal={Sensors},volume={19},number={3},pages={687},year={2019},doi={10.3390/s19030687},}
2018
IROSW
The Aqualoc Dataset: Towards Real-Time Underwater Localization from a Visual-Inertial-Pressure Acquisition System
Maxime Ferrera, Julien Moras, Pauline Trouvé-Peloux, and 2 more authors
In IROS Workshop - New Horizons for Underwater Intervention Missions: from Current Technologies to Future Applications, 2018
@inproceedings{ferrera2018aqualoc,title={The {Aqualoc} Dataset: Towards Real-Time Underwater Localization from a Visual-Inertial-Pressure Acquisition System},author={Ferrera, Maxime and Moras, Julien and Trouv{\'e}-Peloux, Pauline and Creuze, Vincent and D{\'e}gez, Denis},booktitle={IROS Workshop - New Horizons for Underwater Intervention Missions: from Current Technologies to Future Applications},year={2018},}
RFIAP
Odométrie Visuelle Monoculaire en Environnement Sous-Marin
Maxime Ferrera, Julien Moras, Pauline Trouvé-Peloux, and 1 more author
In Reconnaissance des Formes, Image, Apprentissage et Perception (RFIAP), 2018
@inproceedings{ferrera2018rfiap,title={Odom{\'e}trie Visuelle Monoculaire en Environnement Sous-Marin},author={Ferrera, Maxime and Moras, Julien and Trouv{\'e}-Peloux, Pauline and Creuze, Vincent},booktitle={Reconnaissance des Formes, Image, Apprentissage et Perception (RFIAP)},year={2018},}
2017
ORASIS
Localisation autonome basée vision d’un robot sous-marin et cartographie de précision
Maxime Ferrera, Julien Moras, Pauline Trouvé-Peloux, and 1 more author
@inproceedings{ferrera2017orasis,title={Localisation autonome bas{\'e}e vision d'un robot sous-marin et cartographie de pr{\'e}cision},author={Ferrera, Maxime and Moras, Julien and Trouv{\'e}-Peloux, Pauline and Creuze, Vincent},booktitle={ORASIS},year={2017},}
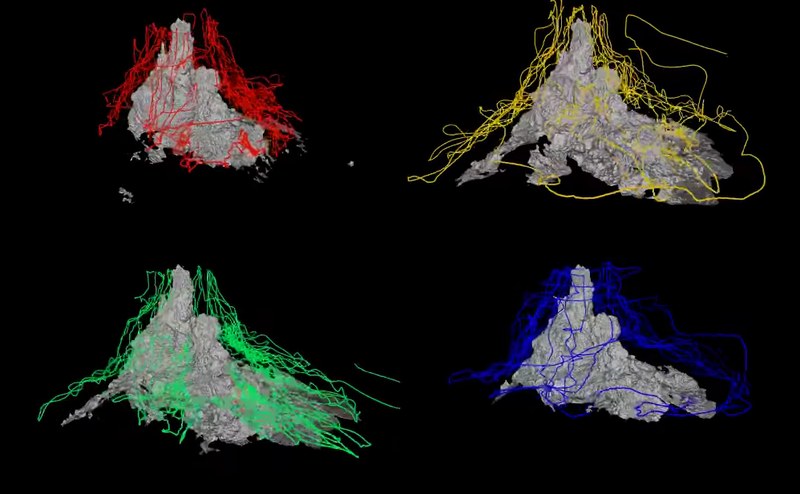
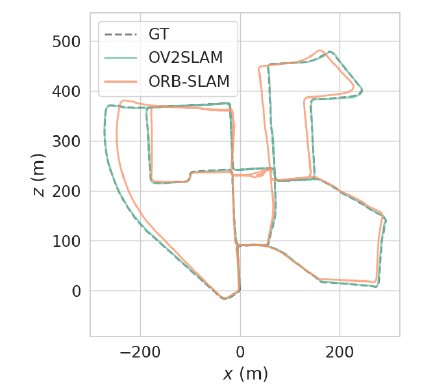
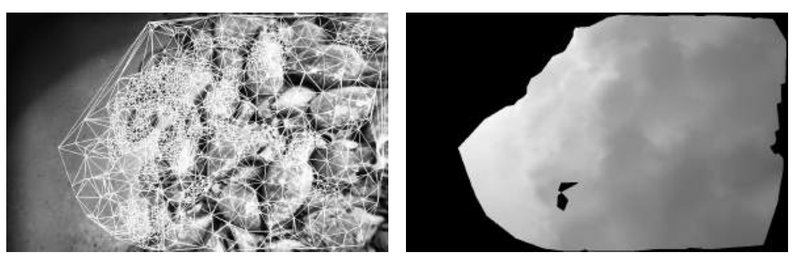 Monocular Visual-Inertial-Pressure Fusion for Underwater Localization and 3D MappingUniversité de Montpellier, 2019